Recognizing intricate metal parts
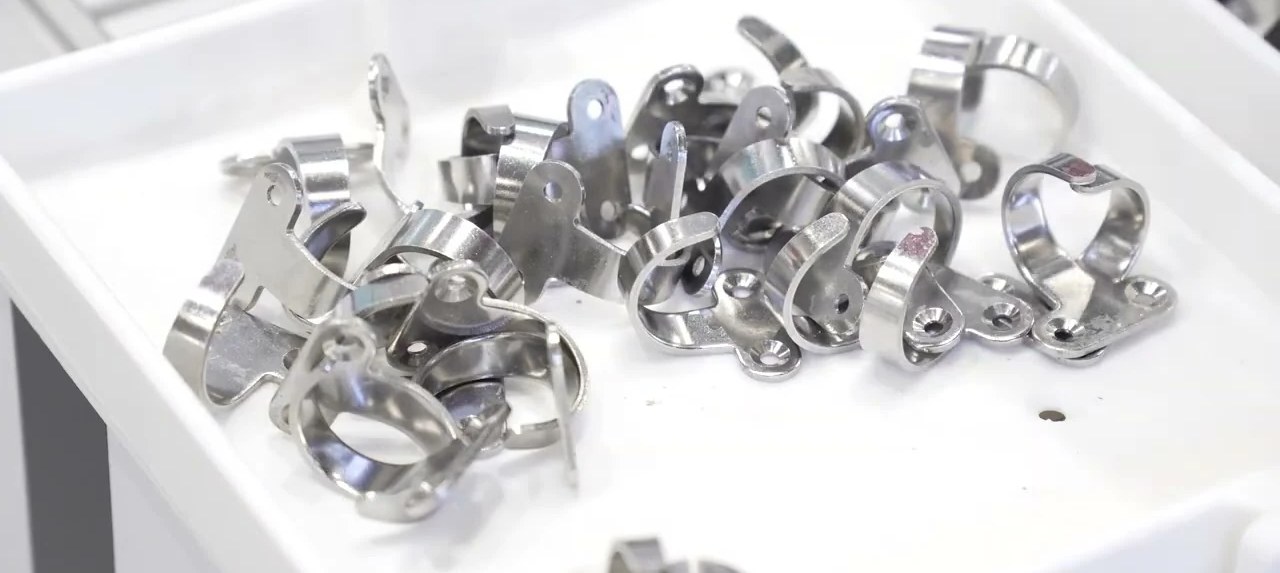
Metallic surfaces and complex hook-shaped features make these components difficult to recognize in 3D. Their random positions and orientations also mean the robot cannot use a fixed approach for every pick.
Eureka combines point-cloud generation with AI models that determine each part’s position and orientation. The underlying perception system supports varied materials and surface properties, including reflective metal and plastic, as well as stable point clouds during in-hand movement.
From the suction point to the fixture
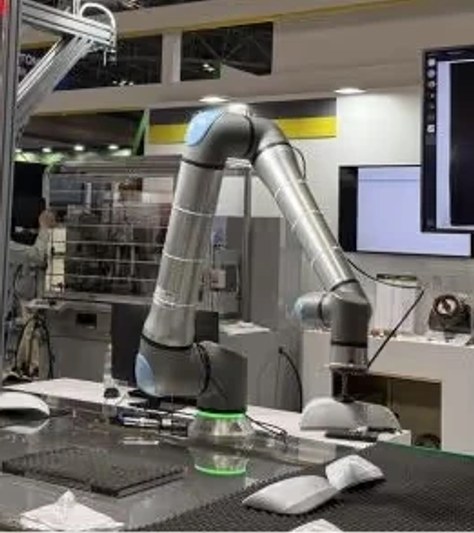
The robot lifts each component with a small suction cup at a designated pick point. Motion planning and control account for the part’s orientation so it can be placed accurately in the fixture, ready for the next operation.