Before you compare cameras, you'll want to decide what you're actually buying:
- A standalone 3D camera that you build your own system around or
- An integrated vision system that arrives ready to pick.
Most manufacturers are better off with an integrated vision system, where one supplier owns the camera, the software and the connection to your robot, so there's far less integration work on your side. A standalone camera makes sense when you want full control, for example when you're developing your own vision software or have an application no existing bin picking system can solve.
Our shortlist of the top 3D camera vendors for bin picking
| Vendor | Category | Technology | What makes it unique |
|---|---|---|---|
| Eureka Robotics | Integrated system | AI stereo | AI stereo camera built specifically for bin picking; The AI identifies parts even when only partially visible, shiny, oily or dark. |
| Mech-Mind | Both | Structured light (LED and laser) | The widest 3D camera range on the market, with its own vision and robot-path software |
| Photoneo (Zebra) | Both | Parallel structured light | Scans parts moving at up to 40 m/s, so it also picks from running conveyors |
| Keyence | Integrated system | Structured light, four cameras | Four cameras and a projector remove blind spots; sold and supported by Keyence directly |
| Pickit | Integrated system | Structured light (Zivid optics) | Camera, processor and picking software in one kit, with native drivers for 18 robot brands |
| Cognex | Standalone camera | Single-shot projected light (3D LightBurst) | Fast single-shot 3D capture inside Cognex's wider machine vision software |
| Zivid | Standalone camera | Structured light | The most rigorously published point-cloud specs, built to mount on the robot |
| IDS Ensenso | Standalone camera | Projected-texture stereo | Projected-texture stereo in rugged housings, including light models for cobots |
| Basler | Standalone camera | Time of flight; active stereo | Time-of-flight and stereo cameras for large, forgiving picks like boxes and sacks |
| SICK | Standalone camera | Time of flight | The only datasheet that quantifies how accuracy drops on dark surfaces |
What makes a bin picking project successful, and where the 3D camera comes in
A bin picking cell succeeds when it empties the bin reliably, within cycle time, and keeps doing so when parts or lighting change. Four factors determine the system's success, and the camera touches all of them:
- A usable point cloud on your parts, from the top layer of a full bin to the floor of an empty one. Shiny, dark and tangled parts are where cameras fail first.
- Software that turns the point cloud into picks: finding the part, choosing a grasp and planning a collision-free path. A great camera with weak software picks worse than a good camera with strong software.
- Cycle time: image capture plus processing has to fit inside the robot's move.
- Integration and support: calibration, the robot and PLC connection, and who you call when picks fail.
How 3D cameras differ
The sensing method decides how a camera copes with your parts.
| Technology | How it works | Strengths | Watch out for |
|---|---|---|---|
| Structured light | Projects patterns onto the bin and triangulates | Fine detail at short and medium range | Reflections on shiny metal; extra exposures cost time; the projector is one more part that can fail |
| Time of flight | Measures how long light pulses take to return | Fast, robust, long range | Too coarse for small parts |
| Classic stereo | Two cameras match pixels between images | Simple, low-cost hardware | Struggles on parts without surface texture |
| AI stereo | Same as classic stereo, but AI also identifies parts correctly in many edge cases. | Similar to human operators, it can identify parts even when only partially visible, dark, shiny, translucent, etc. | - |
3D camera specs, explained
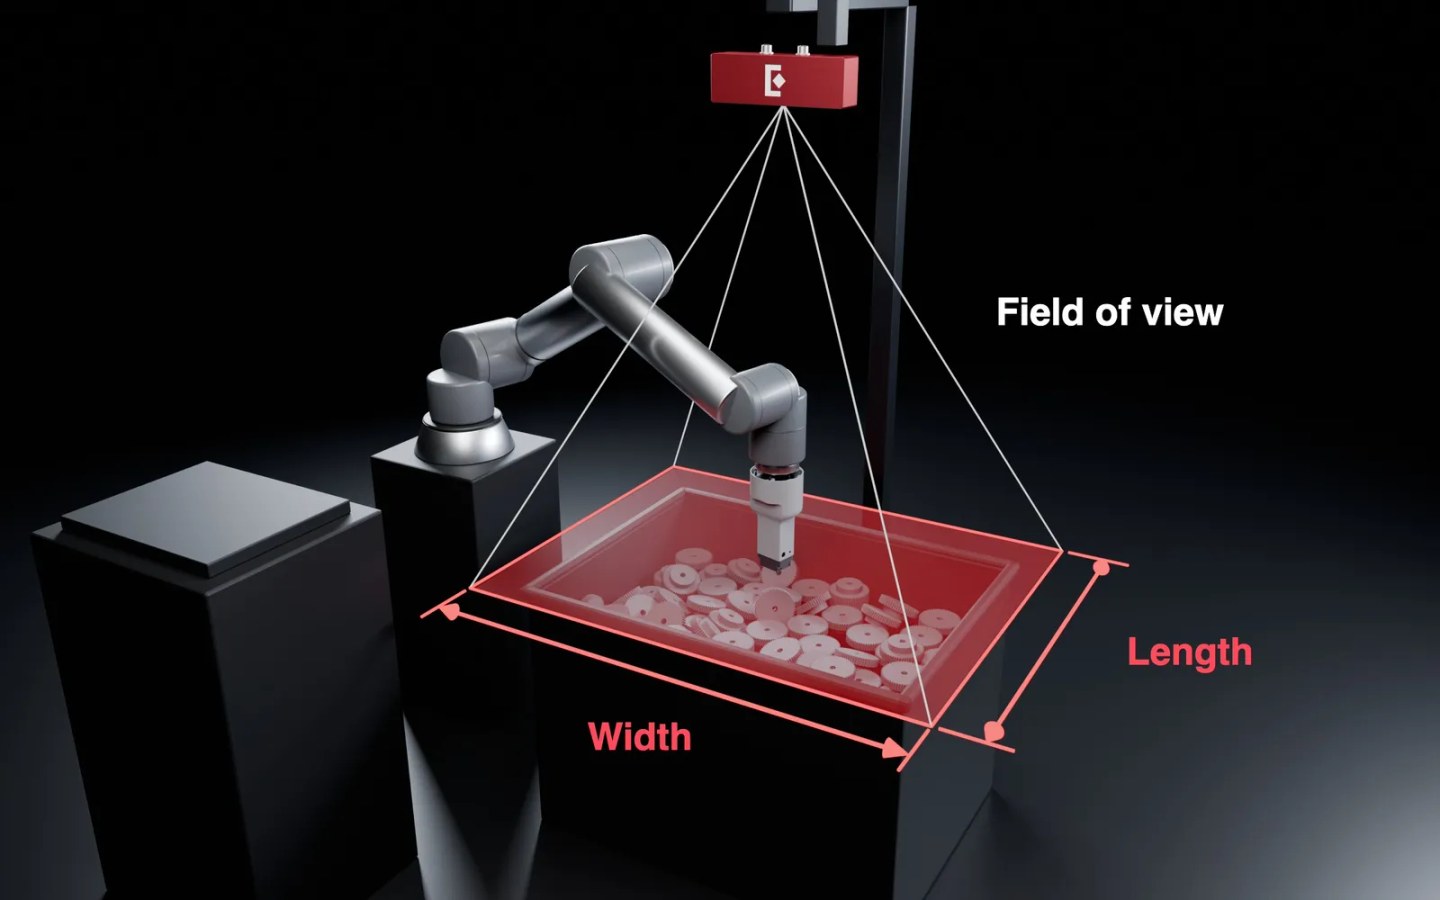
Field of view
The area the camera sees at a given distance. It has to cover the whole bin from where the camera is mounted, and it grows with distance at the cost of resolution. Plan on losing the outer edges of the frame, where accuracy falls off.
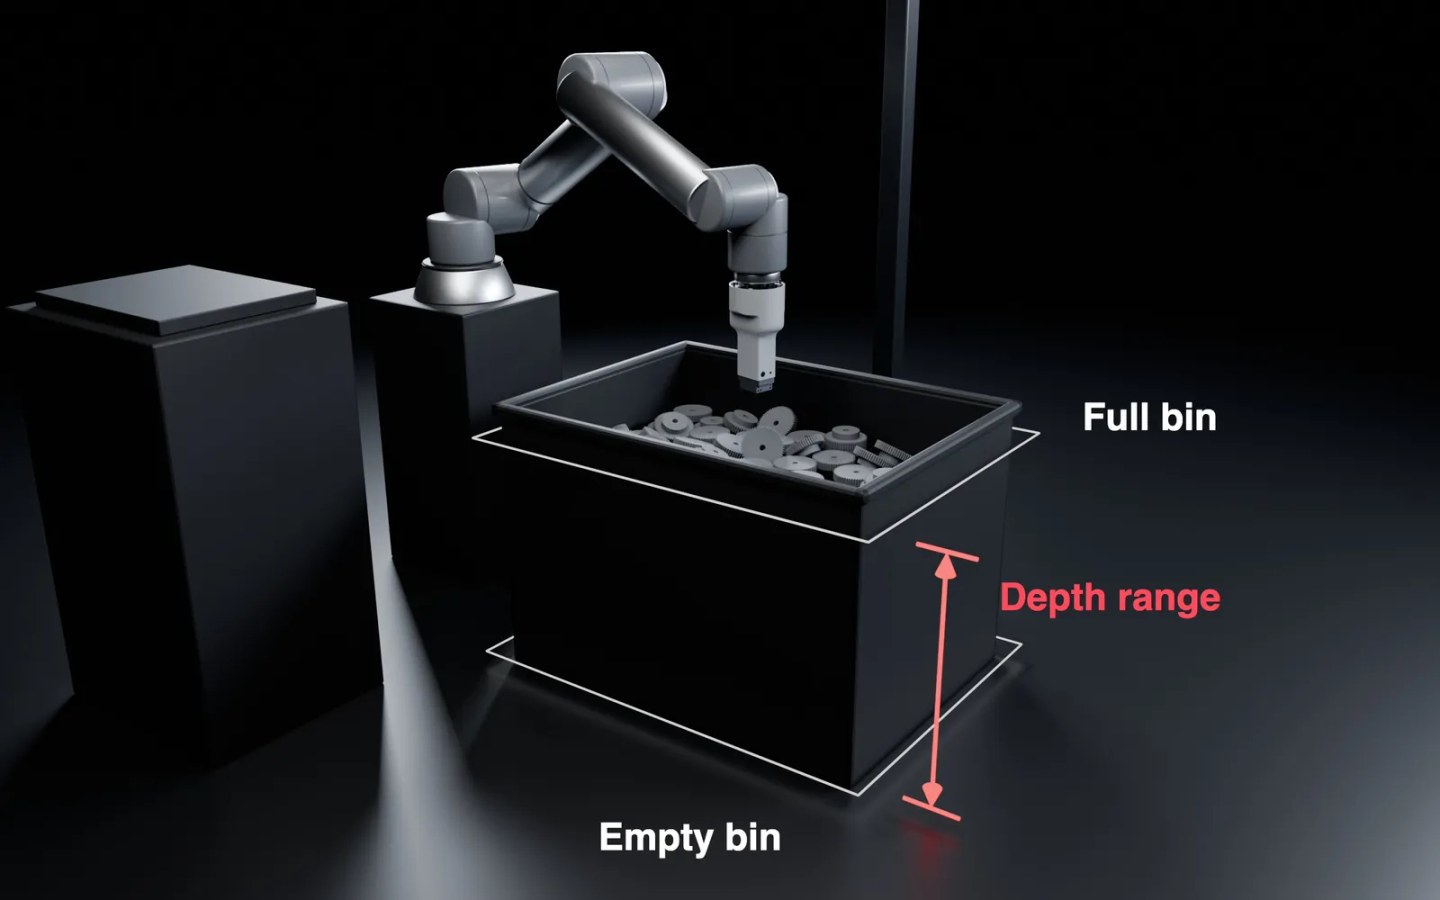
Depth range
The span of distances where the camera returns valid data. It has to reach from the top layer of a full bin to the floor of an empty one. Check which range the accuracy spec applies to: usually the vendor's "optimal" band, not the full rated range.
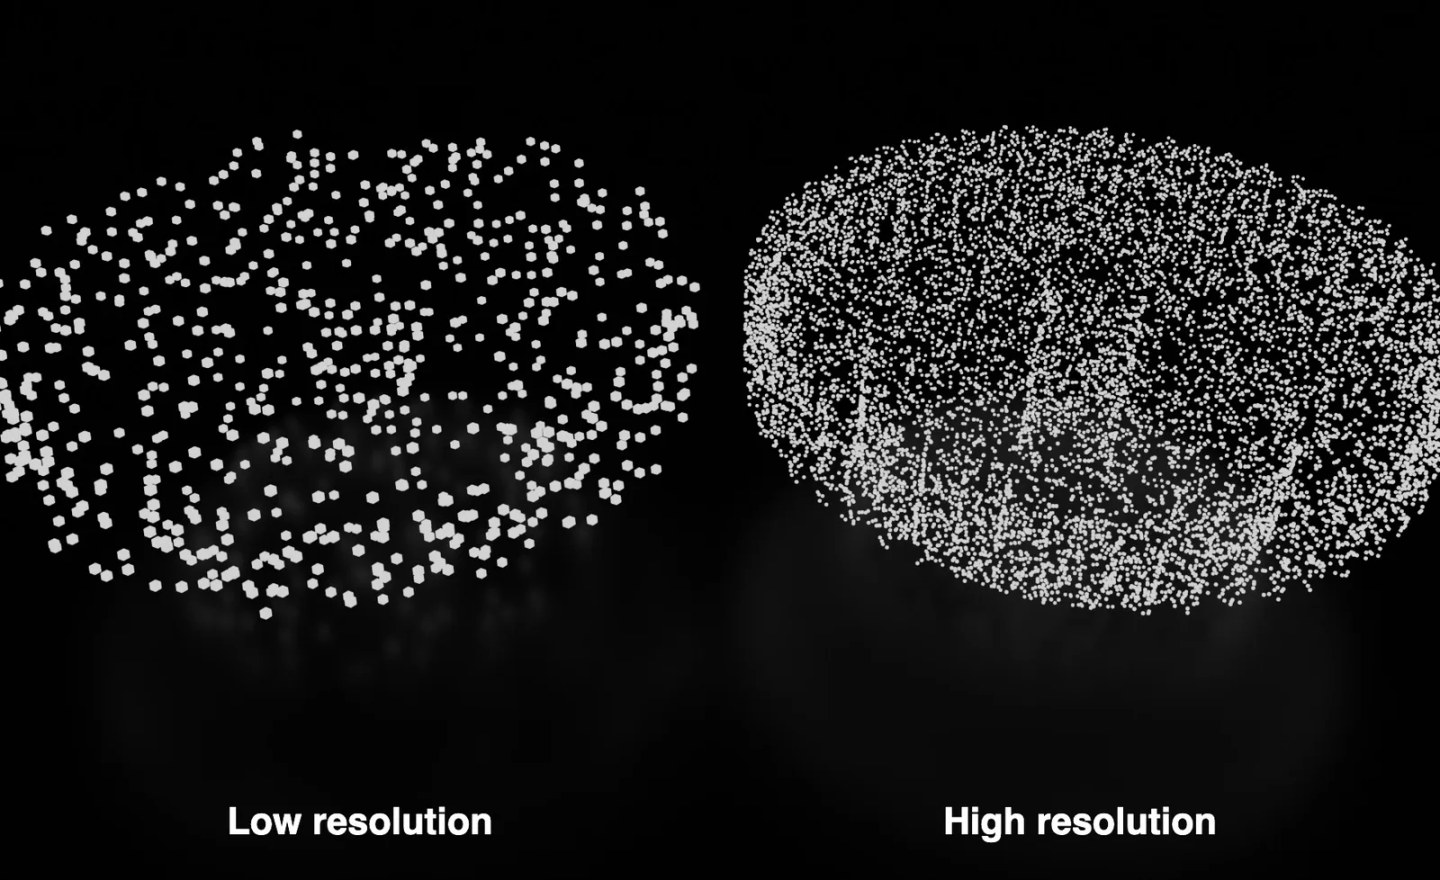
Resolution
The spacing between points on the part, which decides whether small features show up at all. About 0.5–0.8 mm is enough for most parts, 0.25–0.5 mm for small parts and fine features. Spacing grows with distance, so a resolution requirement sets a maximum mounting height.
Higher resolution doesn't automatically mean better picking. Performance depends on all of these factors combined, and on what the software does with the data: the best point cloud doesn't help if the software can't find the part because it's shiny or hidden in a corner of the bin.
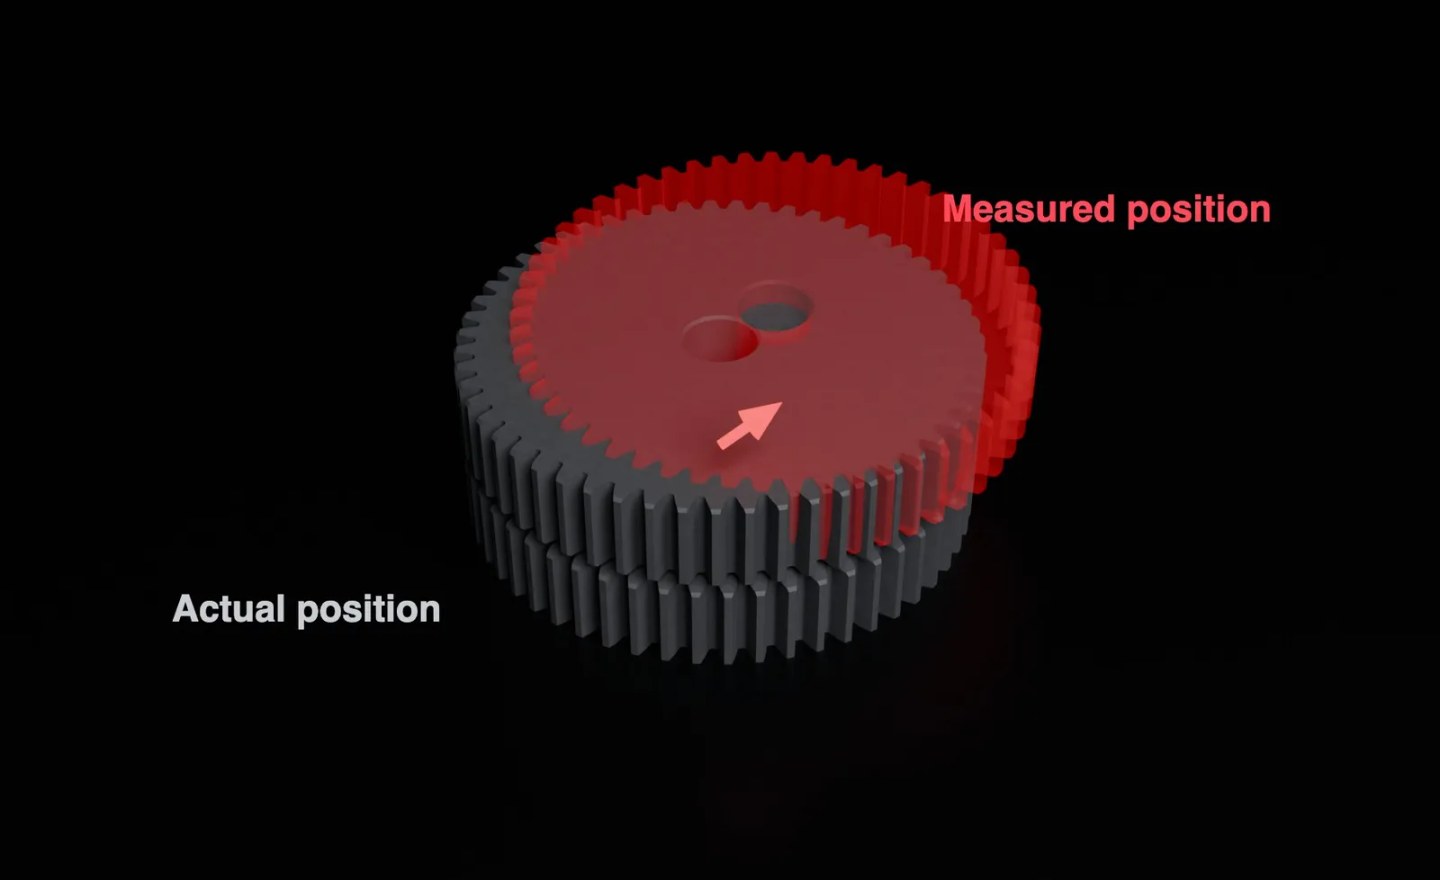
Accuracy
Accuracy combines precision, the variation between repeated captures, and trueness, how close a measurement sits to the real dimension, as defined in ISO 5725. Optical 3D systems are also specified against VDI/VDE 2634, which measures probing error, sphere spacing error and flatness instead, so two vendors' accuracy figures rarely describe the same test. In a picking cell the camera is one of three terms anyway, alongside the hand-eye calibration residual that ties camera coordinates to robot coordinates and the robot's absolute positioning accuracy, which on an uncalibrated arm is considerably worse than its quoted repeatability. Pickit is the only vendor publishing the resulting derating, at roughly 1.5 times camera accuracy.
Surfaces
Material optics change what reaches the sensor. Shiny metal parts reflect projector light straight back at intensities Zivid describes as thousands of times stronger than the rest of the scene, and light bouncing between the part and the bin walls adds ripples and surfaces that do not exist. Dark parts, including many moulded plastic parts, return too little light for the signal to clear the sensor noise floor, so exposures lengthen or get stacked. SICK's Visionary-T Mini datasheet quantifies that: at 2 m, 1-sigma repeatability is about 1 mm against a 90 percent remission target and 4 mm against a 10 percent target, while accuracy stays at plus or minus 3 mm for both. Transparent parts pass light through, and no vendor publishes a measurable specification for them.
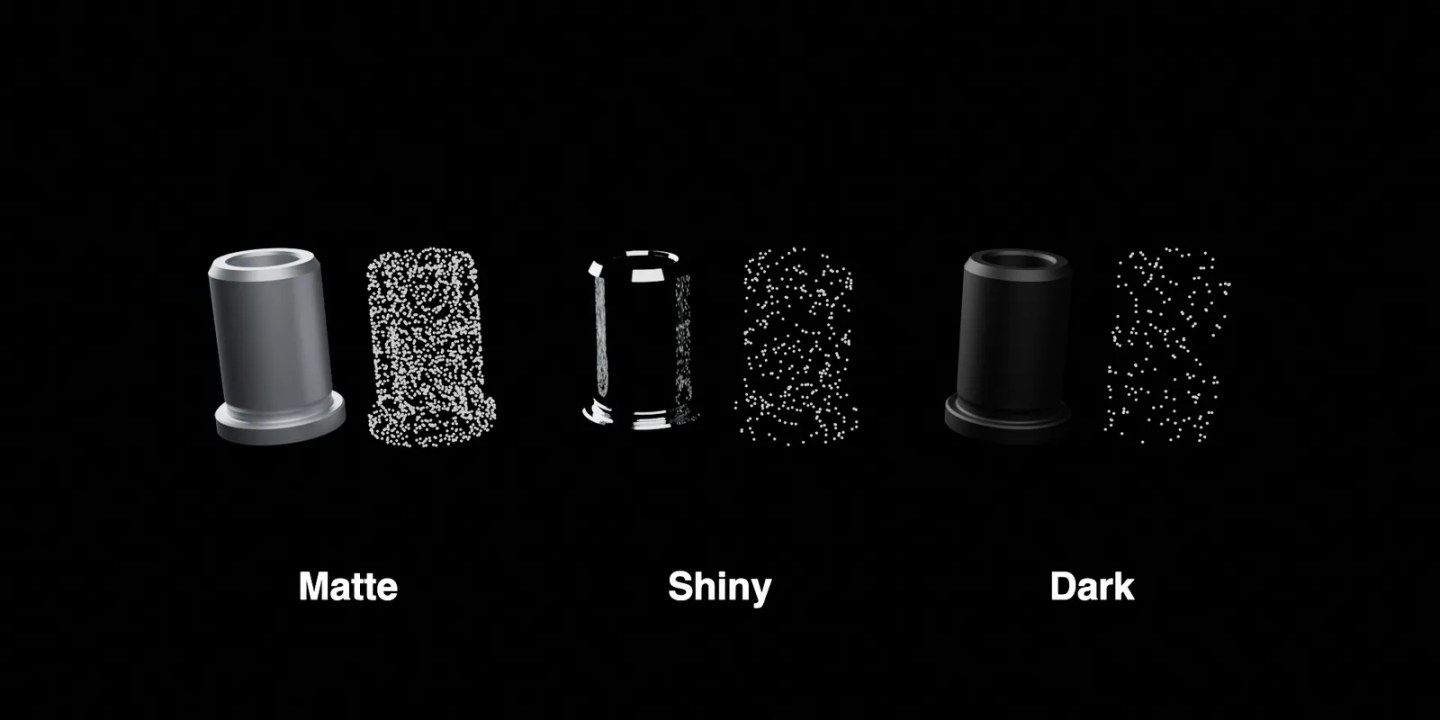
Capture time
The time from trigger to a usable point cloud, which has to fit inside the robot's move: typically under 1.5 s of camera time in a 5–15 s cycle. Difficult parts need extra exposures (HDR), which multiplies it. Check whether a vendor quotes acquisition only or the finished point cloud.
System vendors
1. Eureka Robotics
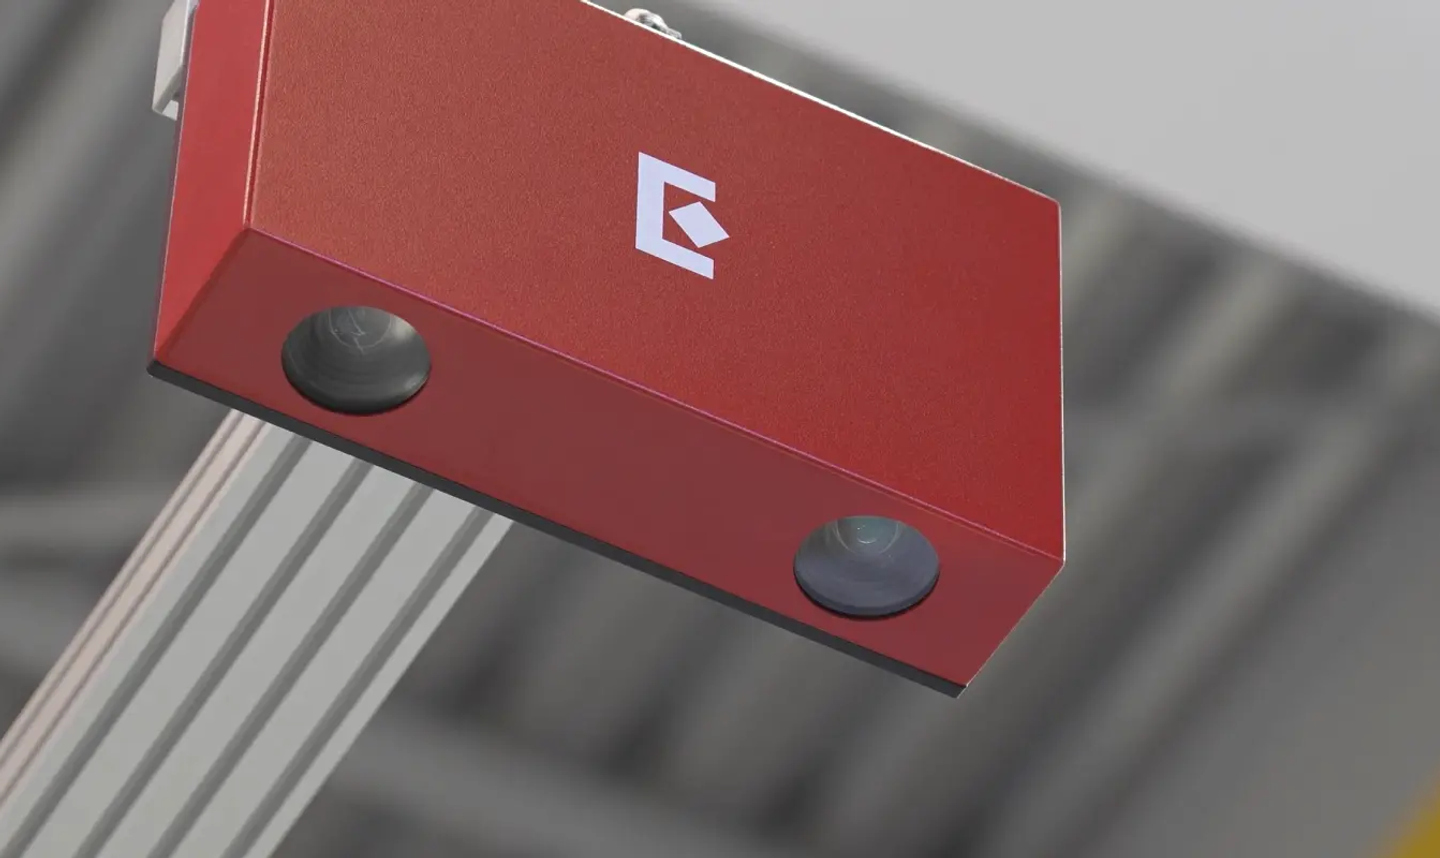
Eureka Robotics' AI Vision System is an integrated solution of 3D camera, controller and StereoPick software, specifically created for bin picking. The camera uses AI stereo vision with an optional projector, in three working ranges from 300 mm to 4 m.
A super-model trained on millions of parts, together with software accessible to entry-level users, reduces deployment time by months compared to conventional vision projects. Simple parts need no CAD and no training. The system integrates with any robotic arm, runs on site with no cloud connection required, and is a one-time purchase with no subscription (edge AI model training, a privacy option, is a paid add-on).
The Eureka AI Vision System is deployed in production at manufacturers like Pratt & Whitney and Subaru, and has completed more than 30 million picks.
The Eureka 3D Camera up close
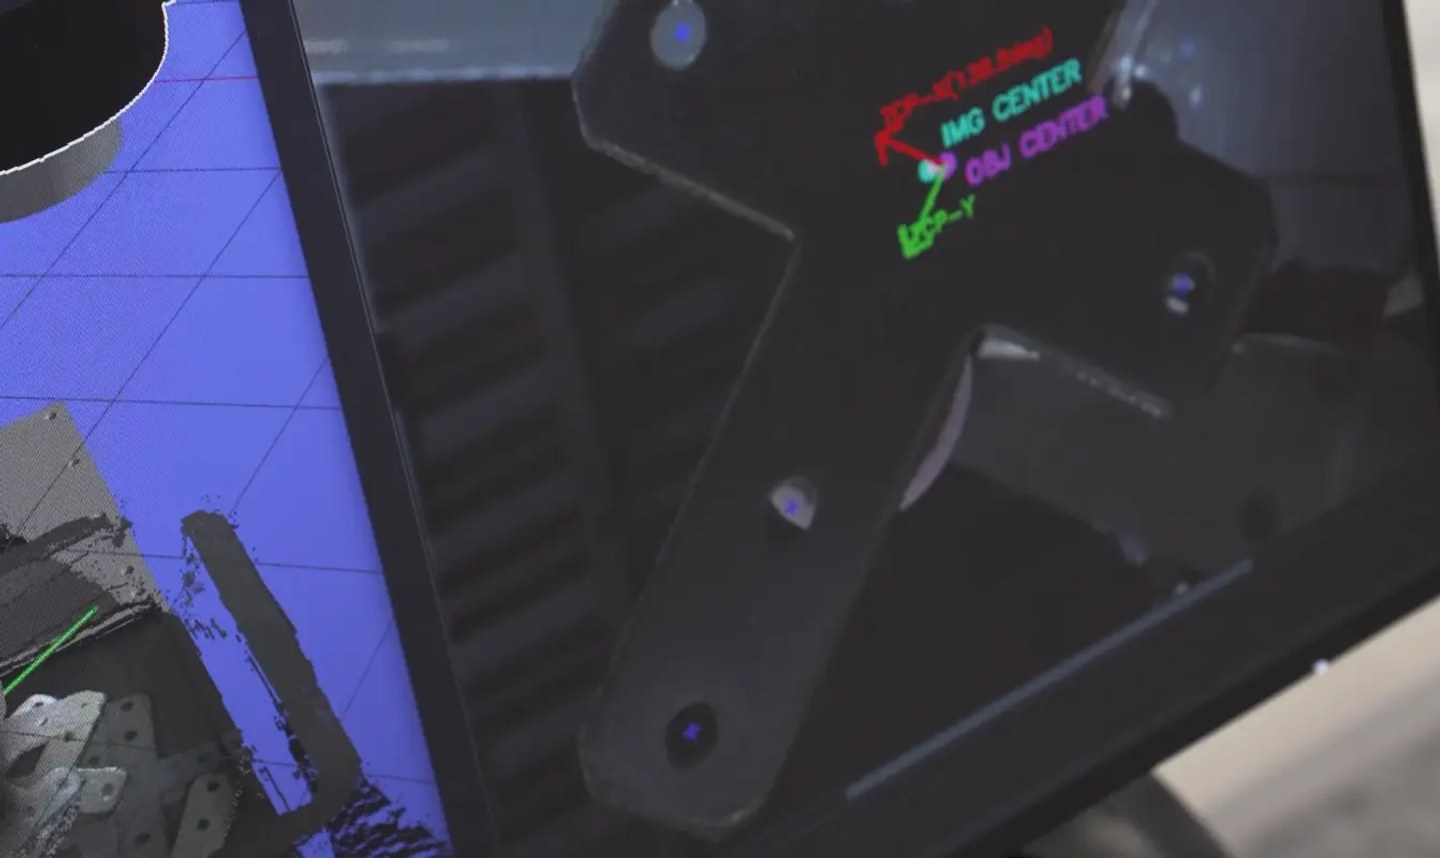
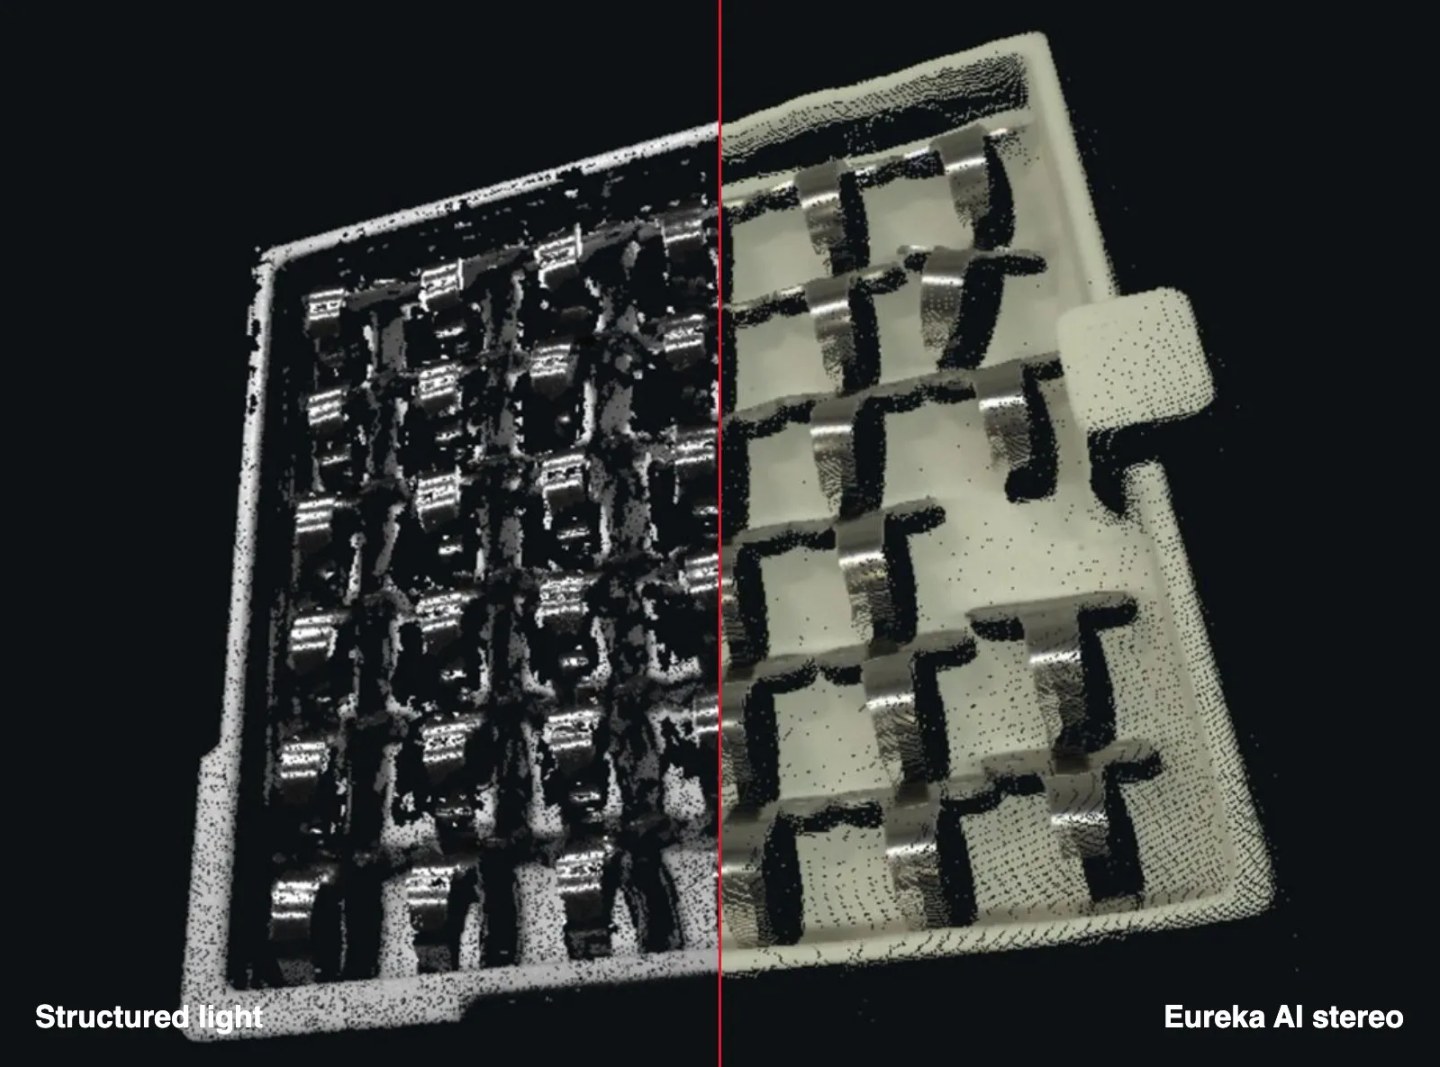
The camera computes depth with two lenses and a neural network instead of projecting a pattern onto the parts. That matters most on shiny metal: a projected pattern bounces off the surface and leaves holes in the point cloud, while AI stereo still sees the part. The two scans below show the same tray of shiny clips.
- Three working ranges: 300–600 mm, 600–1200 mm and 1200–4000 mm
- Sensor: 1.6 MP global shutter, up to 1440 × 1080
- Speed: 0.1–1.2 s capture
- Connection: GigE Vision with Power over Ethernet
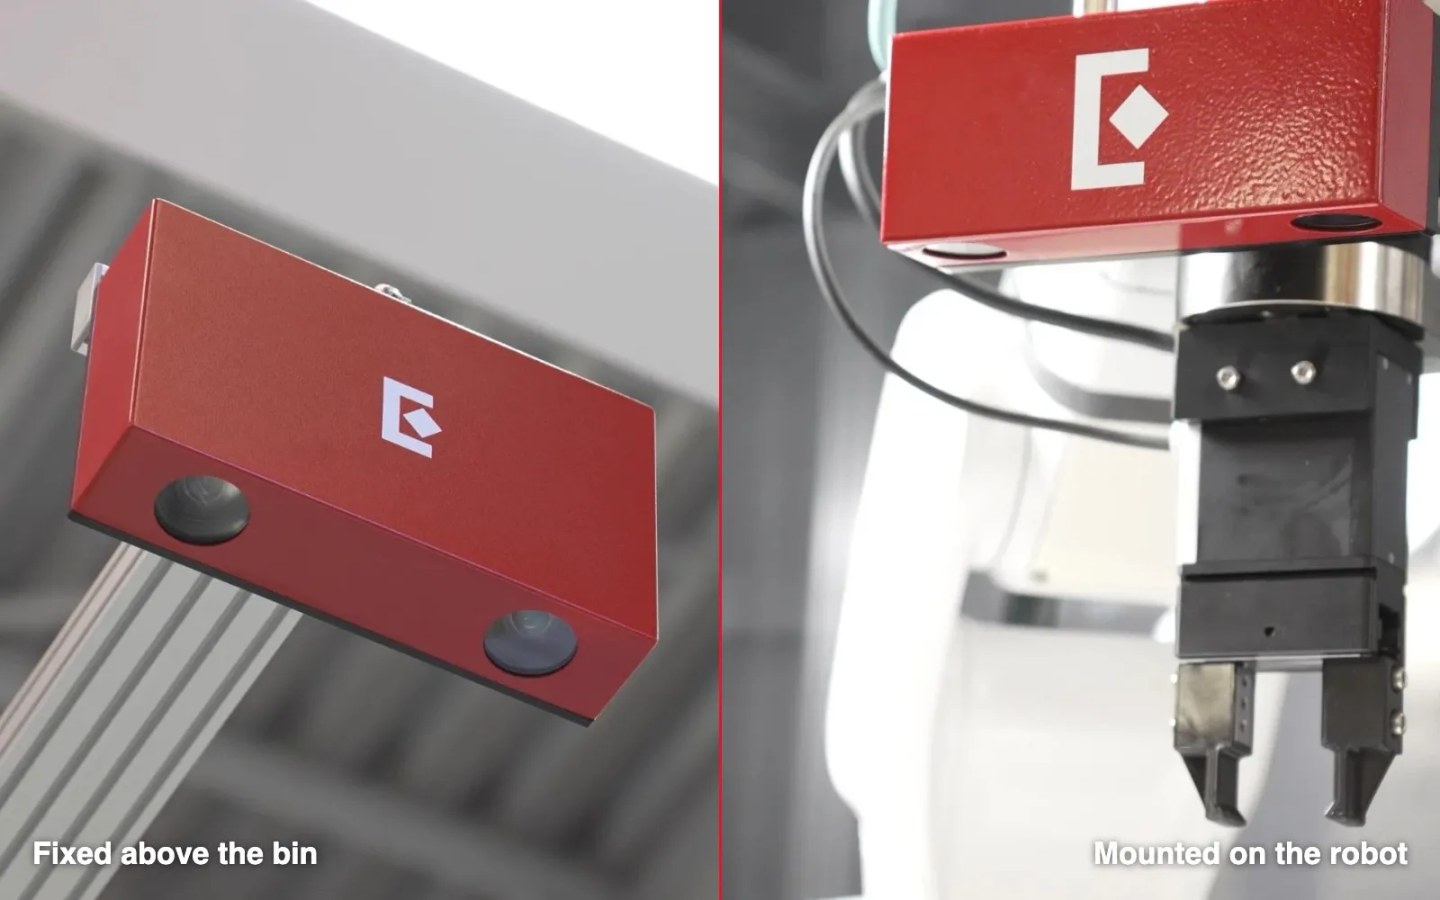
- Options: pattern projector for parts without surface texture; mounts above the bin or on the robot
2. Mech-Mind
Mech-Mind sells the Mech-Eye camera range together with Mech-Vision, Mech-Viz and Mech-DLK, its software for vision, robot programming and deep learning.
Ten camera models cover working distances from 300 mm to 3500 mm, and the published specification table is the most complete of any vendor in this list. A high dynamic range structured light mode on the LSR, PRO and DEEP cameras is aimed at dark and reflective surfaces, with a claimed 95 percent reduction in missing and distorted points on mirror-finish metal. The software integrates with more than 1,000 robot models.
3. Photoneo
Photoneo, owned by Zebra Technologies since 2025, sells MotionCam-3D cameras and PhoXi 3D scanners, with Bin Picking Studio as the picking application on top. The hardware is also sold on its own with an SDK, so Photoneo sits in both halves of this market.
Its distinguishing feature is motion tolerance. MotionCam-3D acquires data in 10 ms at up to 20 fps and is rated for object speeds to 40 m/s, which suits picking from a moving conveyor as much as from a static bin. Bin Picking Studio takes CAD of the cell and the gripper to check for collisions before a pick is committed.
4. Keyence
Keyence sells 3D vision-guided robotics as a closed system of imaging unit, controller and setup software.
The imaging unit uses four cameras and one projector, capturing 136 images per scene, with the four-camera geometry intended to remove blind spots. Path planning, automatic robot-camera calibration and a picking simulator are included, and the system re-scans after every pick. Keyence publishes no working distance, field of view, accuracy or capture time for any model on the open web, so an evaluation runs through a sales conversation rather than a datasheet.
5. Cognex
Cognex sells the 3D-A5000 area scan camera alongside its wider machine vision software ecosystem.
The camera uses what Cognex calls 3D LightBurst to return a full field of view point cloud in as little as 200 ms, built from more than 1.5 million data points, factory calibrated and rated IP65, in standard and extended working volume variants. As with Keyence, working distance and accuracy are not published openly.
6. Pickit
Pickit sells a camera, a rack-mounted processor, picking software and robot integration as one package. It does not manufacture sensors: the current HD2 range is built on Zivid optics.
Pickit is the most transparent vendor here about real-world performance. It publishes a part picking accuracy and a part location accuracy separately for every model, and states that picking accuracy runs about 1.5 times the camera's own accuracy, measured in production environments rather than in a laboratory. Every model supports both fixed and robot-mounted installation.
Hardware vendors
1. Zivid
Zivid sells structured light cameras with an SDK and no picking layer. Detection, pose estimation, grasp planning and the robot interface are the integrator's work.
Its specifications are the most rigorous published in this market, separating point precision, planarity and dimension trueness, each with its test conditions stated, and its public knowledge base is the best technical reference any vendor in this article offers. The 2+ family shares a 5 MPx sensor, an IP65 rating, 1000 g weight and a 10 GigE interface, and needs a 10 minute warm-up before the accuracy specification applies.
2. Basler
Basler sells two families through its pylon SDK. The blaze is a time-of-flight camera at 640 by 480 px covering 0.3 to 10 m, with typical depth accuracy of plus or minus 5 mm and an IP67 rating, offered at 850 nm for indoor use and 940 nm where daylight is a problem. The Stereo ace is an active stereo camera at 2472 by 2064 px with 100, 200 or 300 mm baselines.
VGA resolution puts the blaze outside small-part bin picking. Both families suit large, forgiving picks such as boxes and sacks.
3. IDS Ensenso
IDS sells projected-texture stereo cameras in several families. The N series is built for rough environments and supports arm mounting, with the lighter N4x housings aimed at collaborative robots. The X series is modular, with a 100 W projector and working distances beyond 5 m. The C and CR series are rated IP65 or IP67, and CR models compute depth on the camera itself.
IDS publishes a reproducible Z accuracy of 0.2 mm at 2 m for large-baseline narrow-field models, and around 0.4 mm at 3.5 m for the longer ones. Per-model figures come from a camera selector tool rather than published tables.
4. SICK
SICK sells the Visionary-T Mini, a time-of-flight snapshot camera at 512 by 424 px, rated IP65, IP67 and IP69, weighing 520 g, with ambient light immunity to 50 klx.
Its resolution places it outside precision bin picking. Its datasheet, however, is the most useful document in this market for anyone with dark parts, because it publishes accuracy and repeatability against target remission, distance and temperature. That is the only quantified account of the dark-surface penalty described below.
5. Intel RealSense
RealSense sells low-cost stereo depth cameras with an open SDK. The D455 covers 0.6 to 6 m at up to 1280 by 720 px, with depth accuracy stated as under 2 percent at 4 m and a published list price of $419. The D457 is the IP65 variant.
That accuracy works out to roughly plus or minus 80 mm at 4 m, two orders of magnitude away from the structured light cameras above. It belongs to a different tier and is included for scale, and because Inbolt uses one as the standard camera in its own guidance system.
Vendor specs compared
| Model | Technology | Working distance | Resolution | Accuracy, vendor's own metric | Capture time | Sold as |
|---|---|---|---|---|---|---|
| Eureka ECA-S-3001 | AI stereo, passive (no laser); projector optional | 300–600 mm | 1440 × 1080 | Expected depth error 0.26–1.04 mm (calculated); lateral 0.17–0.35 mm/px | 100–1200 ms typical | System |
| Eureka ECA-M-3002 | AI stereo, passive (no laser); projector optional | 600–1200 mm | 1440 × 1080 | Expected depth error 0.80–3.18 mm (calculated); lateral 0.35–0.69 mm/px | 100–1200 ms typical | System |
| Eureka ECA-L-3002 | AI stereo, passive (no laser); projector optional | 1200–4000 mm | 1440 × 1080 | Expected depth error 3.18–35.38 mm (calculated); lateral 0.69–2.3 mm/px | 100–1200 ms typical | System |
| Zivid 2+ MR60 | Structured light | 300–1100 mm, optimal 350–900 | 2448 × 2048 | 80 µm point precision; trueness under 0.20% typical, under 0.35% full temp | 25–1500 ms | Camera + SDK |
| Zivid 2+ MR130 | Structured light | 800–2700 mm, optimal 1000–1600 | 2448 × 2048 | 210 µm point precision; trueness under 0.35% typical, under 0.60% full temp | 25–1500 ms | Camera + SDK |
| Zivid 3 XL250 | Structured light, laser | 1500–4000 mm | 8 MPx | 250 µm point precision; trueness under 0.2% | 250–1500 ms | Camera + SDK, fixed mount only |
| Photoneo MotionCam-3D M | Parallel structured light | 497–939 mm | 1680 × 1200 | Under 0.500 mm camera mode, under 0.250 mm scanner mode | 10 ms acquisition | Camera + SDK, or Bin Picking Studio |
| Mech-Eye PRO M-GL | Structured light | 1000–2000 mm | 1920 × 1200 | 0.2 mm Z-repeatability and VDI/VDE at 2 m | 0.3–0.6 s | Camera + software suite |
| Mech-Eye LSR L-GL | Structured light | 1200–3000 mm | 2048 × 1536 | 0.5 mm Z-repeatability, 1.0 mm VDI/VDE at 3 m | 0.5–0.9 s | Camera + software suite |
| Pickit L-HD2-MR130 | Structured light (Zivid optics) | 800–2700 mm | 2448 × 2048 | 3.0 mm picking, 1.0 mm part location | From 200 ms | System |
| Basler blaze-102 | Time of flight | 0.3–10 m | 640 × 480 | ±5 mm typical, 0.5–5.5 m | 30 fps | Camera + SDK |
| Basler Stereo ace 100 mm | Active stereo | 0.6–2 m | 2472 × 2064 | 0.28 mm depth resolution at 1 m (quantisation step, not accuracy) | 3–10 fps | Camera + SDK |
| SICK Visionary-T Mini | Time of flight | ≤16 m | 512 × 424 | ±3 mm at 2 m; repeatability 1 mm at 90% remission, 4 mm at 10% | ≤30 fps | Camera + SDK |
| RealSense D455 | Active stereo | 0.6–6 m | 1280 × 720 | Under 2% at 4 m, so ±80 mm | Up to 90 fps | Camera + SDK, $419 list |
| Keyence 3D VGR | Structured light, four cameras | Not published | Not published | Not published | Not published | System |
| Cognex 3D-A5000 | 3D LightBurst | Not published openly | 1.5M points | Not published openly | From 200 ms | System |
| IDS Ensenso C | Projected stereo | To 3.5 m | Not published openly | 0.2 mm Z at 2 m, 0.4 mm at 3.5 m | Not published openly | Camera + SDK |
FAQ
Which 3D cameras are suitable for bin picking?
Any camera that gives you a usable point cloud of your parts across the full bin depth, inside your cycle time.
Structured light cameras are popular (Zivid, Photoneo, Mech-Mind, Keyence) but struggle with reflections and transparent parts. Eureka Robotics' AI stereo camera is a robust option since it was specifically designed for bin picking.
The software that turns the camera's point clouds into robot instructions for picking is equally important. A great point cloud is useless without strong bin picking software.
What are the alternatives to Mech-Mind or Photoneo?
Both sell structured light cameras with their own picking software. For a complete system, the alternatives are Eureka (AI stereo, works with any robot brand), Keyence, Pickit and Cognex. For hardware only, Zivid is the closest match, and you bring your own software. The vendor overviews above cover each one.
Do I need a 3D camera, or is 2D enough?
If parts sit in neat layers, 2D plus a height check (a laser distance sensor or a known layer pitch) often does the job for less money.
Once parts are randomly piled, tilted or overlapping, you need 3D: the robot needs the full pose of the part, not just X, Y and rotation.
Should I use my robot maker's 3D vision or a third-party system?
Robot-brand vision such as FANUC iRVision runs in the controller and pendant, so it's the easiest to set up and maintain, and it handles layered parts well.
For truly random bins, engineers report noticeably better pick rates from dedicated vision systems, which also work across robot brands if your plant runs more than one.
How do I choose a 3D camera by working distance?
Measure the distance from the mounting point to the top of a full bin and to the floor of an empty one. Pick a camera whose optimal range, not its rated range, covers both, then check the field of view at the far end still contains the whole bin.
Which 3D camera works on shiny, dark or clear parts?
Shiny metal reflects the projector and leaves holes in the point cloud; dark parts return too little light. Structured light cameras fight this with HDR and multiple exposures, which adds capture time. AI stereo needs no projector, so it avoids the reflections, but it relies on a trained model. Clear parts defeat most cameras. No spec sheet answers this reliably: Ask for a point cloud of your own parts at your own distance.
Should the camera be fixed above the bin or mounted on the robot?
Fixed mounting saves cycle time because the camera can image while the robot moves; trigger the next capture as soon as the arm clears the field of view. Robot mounting lets one short-range camera cover large or multiple bins and see into corners, at the cost of an extra move per pick.
What does a 3D camera for bin picking cost?
Camera list prices are rarely published. Expect the vision system, meaning camera, software and engineering, to cost $30,000 to $60,000, and most of that is software and integration, not the camera. A $400 depth camera like a RealSense is tempting but rarely accurate enough for industrial picking. Our buyer's guide compares the vendors.
Related reading
Grippers for bin picking, the bin picking field guide on cell design, and the buyer's guide on vendor selection.
Send us a bin of your parts and we return a pick video and a written verdict within 72 hours.