
The eyes
Eureka 3D Camera
Stereo 3D capture of cluttered bins, including reflective and dark parts. Fixed or arm-mounted.
Explore the 3D Camera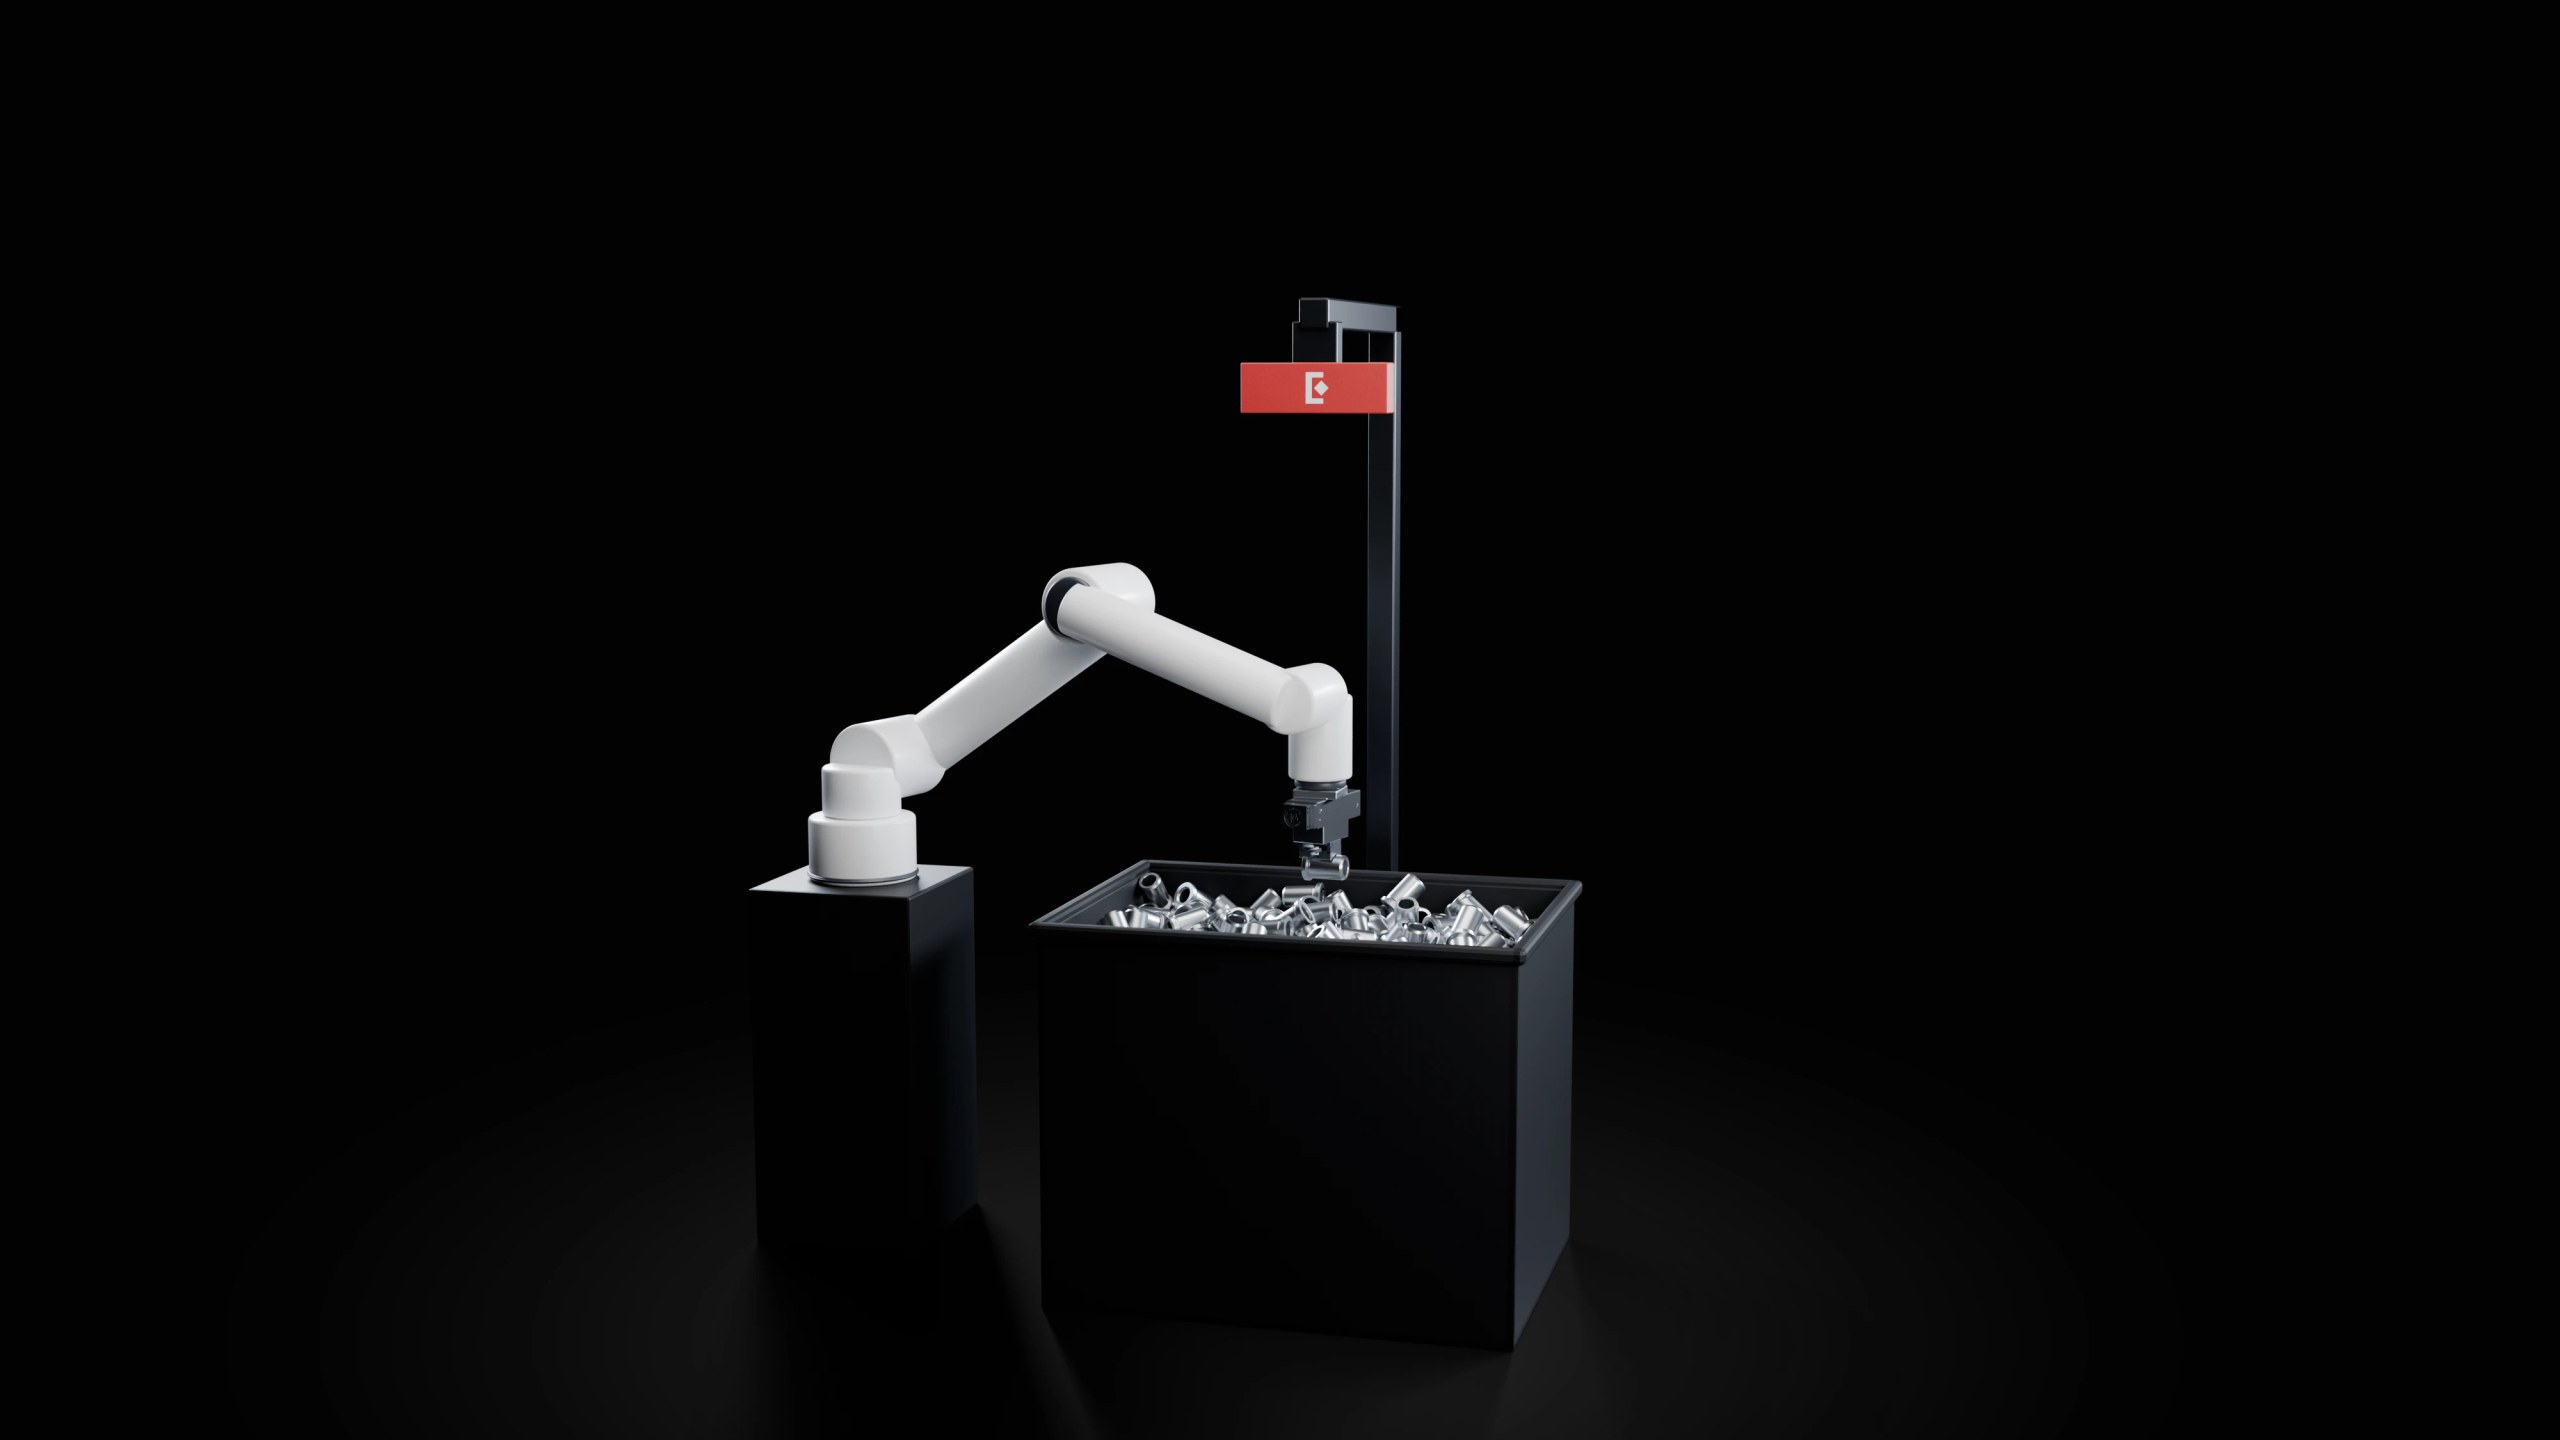
3D camera, controller and StereoPick software that guide your robot to pick shiny, dark and tangled parts from cluttered bins.
Bin picking is a robot taking randomly piled parts out of a bin and placing them in a defined position. A 3D camera scans the bin, vision software finds a part and its pose, and the robot picks it without trays, feeders or manual loading.
The Eureka AI Vision System does the camera, vision and path planning. Your robot does the picking.
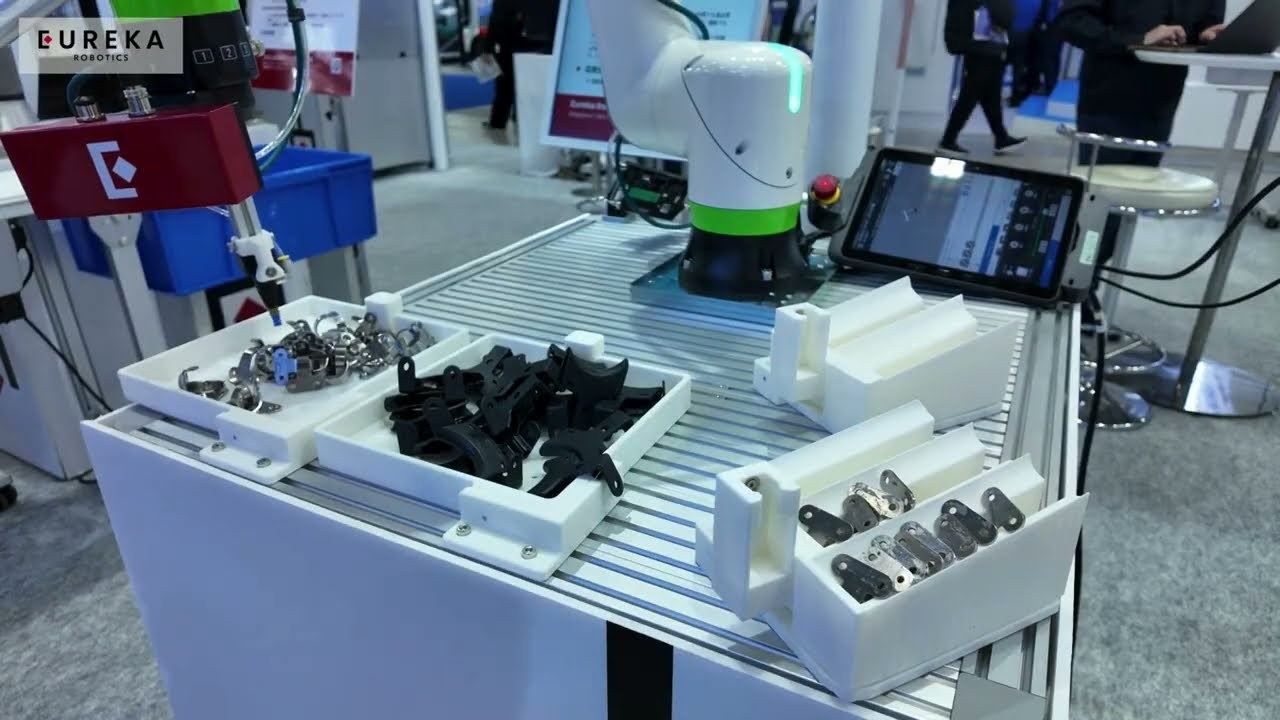
Reflective parts that hook and overlap
The Eureka AI Vision System is a 3D camera, a controller and StereoPick software, built to work together out of the box.
Stereo 3D capture of cluttered bins, including reflective and dark parts. Fixed or arm-mounted.
Explore the 3D Camera
Industrial PC that runs pre-trained AI models locally. Your CAD and images stay on-site.
See the controller
Set up applications, validate in simulation and train new parts in-house. Built for entry-level users.
Explore StereoPickSet up a new application in StereoPick, then run it on the controller.
Click through the StereoPick software, from CAD file to live picksTap through the StereoPick software, from CAD file to live picks
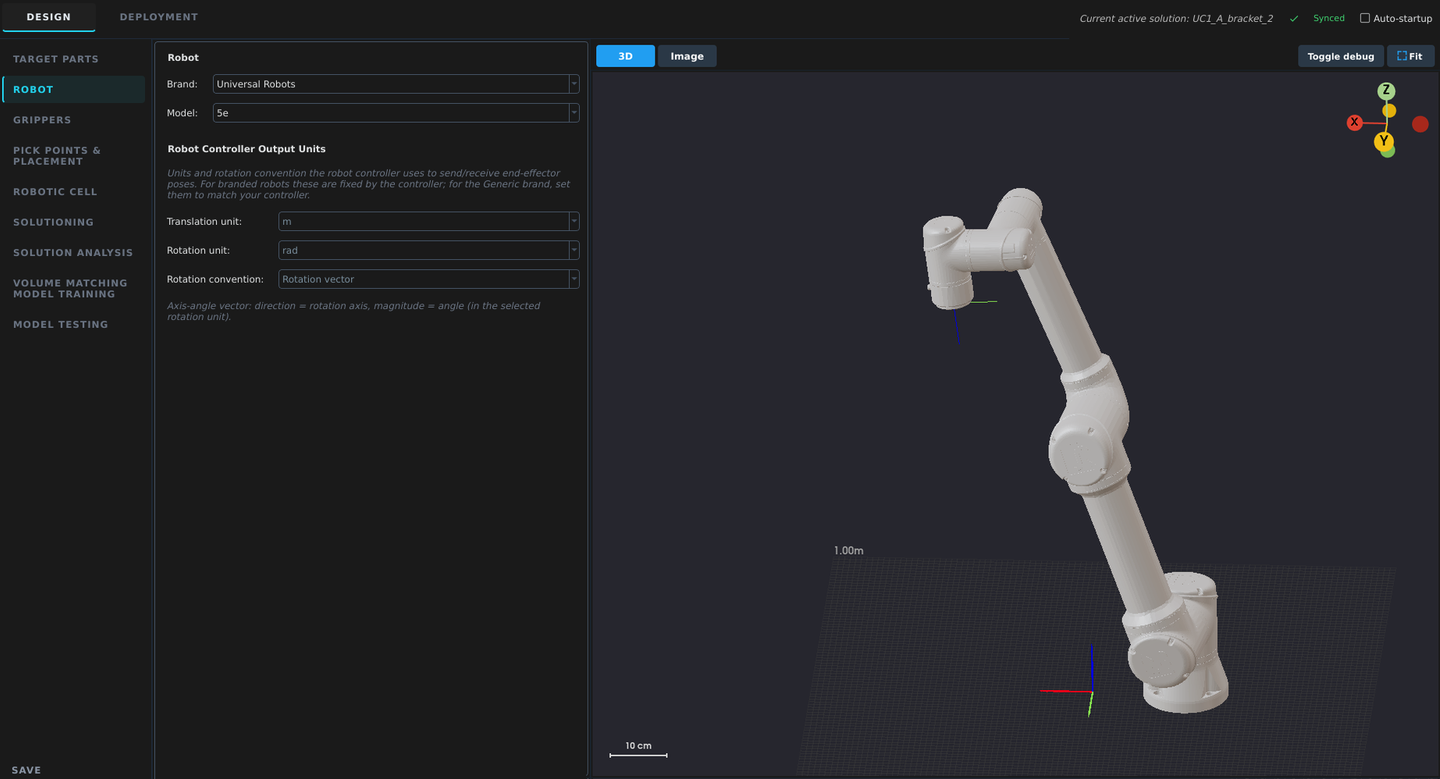
Choose your robot brand and model. StereoPick loads its kinematics and connection settings.
A 3D camera scans the bin, AI software finds the parts and their poses, and the controller chooses one the gripper can reach without collisions. It plans the path, the robot picks and places the part, and the next scan runs while the robot moves.
Rigid metal and plastic parts with a CAD file work well, including shiny, dark, overlapping and entangled parts. Boxes, bags and pouches can be picked without CAD when a rough grasp is enough. Plain, textureless parts may need the optional pattern projector. The free feasibility check tells you where your part stands.
Production cells typically run 4–8 s per pick, with 98–99.9% pick success after tuning. The vision pipeline takes 0.2–0.7 s, and with a fixed camera it runs while the robot moves. Your parts, gripper and cell decide the final numbers, which the feasibility check measures on your samples.
Not always. Masterless picking needs no CAD and no training, and works when a rough grasp is enough. For an exact grasp and placement, AI CAD Matching needs a CAD file for each part and trains in simulation with 0 to 10 real images.
Fanuc, ABB, Universal Robots and AUBO are supported out of the box. Other robots connect through the open socket API.
Not necessarily. StereoPick is built so your own engineers can set up and run applications, with Eureka available to help. If you want someone to deliver the full cell, work with a Eureka-trained integrator in your region.
It depends on the part and the cell. Training and tuning a simple, rigid part with defined part presentation takes a few hours in StereoPick. Complex parts and full production deployment take longer. The free feasibility check gives you an estimate for your application.
The system is a one-time purchase with no subscription, and it runs on-site. For pricing, system configuration and lead times, talk to sales.
Tell us about your application and send us your parts. You get a pick video or live demo within 72 hours of receiving them.
Free. No PO, no NDA, no upfront cost.