Picking a connector in motion
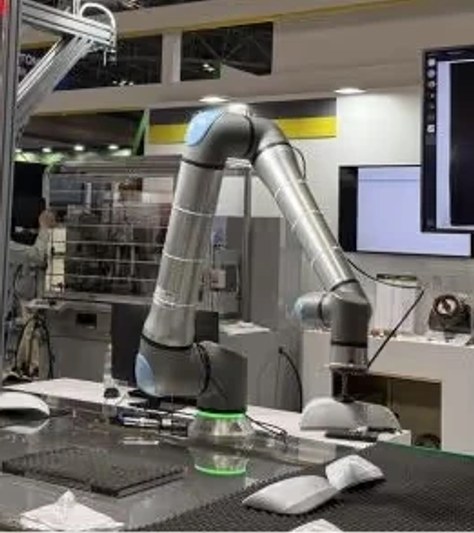
Wire-harness assembly combines a moving target with a contact-sensitive insertion. The robot must locate and grasp the connector while it is moving, then apply enough insertion pressure without damaging pins or forcing a misaligned connection.
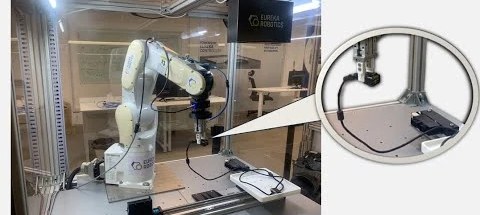
The Eureka 3D Camera and AI determine the male connector’s orientation on the slider. The robot times its grasp to the motion and brings the connector into alignment with the corresponding female connector.
Guiding insertion through contact
A force-torque sensor measures contact in real time. Using that feedback, the robot regulates the force it applies and guides the connectors together. Vision supports tracking, grasping and alignment; force control manages contact as the connectors mate.
The application brings moving-part tracking and precision insertion into one automated sequence. It replaces a manually performed operation with coordinated robotic handling, supporting more consistent assembly and productivity.